Full-range Micro Motor Solutions
We specialize in hybrid stepper motors, BLDC motors and stepper drivers, producing 3 million units annually. Our products serve automated equipment in printers, ticket printers, engravers, medical instruments, stage lighting and textile machinery.
Inquire Now Contact Us| 最大径向力 | Maximum radial force | 610(N) |
| 最大轴向力 | Maximum axial force | 390(N) |
| 操作温度 | Operaring temp | -10℃~+90℃ |
| 平均寿命 | Average lifetime | 15000(s1) 30000(s5) (hr) |
| 噪音 | Noise | ≤60(DB) |
| 润滑油 | Lubrication | Synthetic Grease |
| 防护等级 | Protection class | IP65 |
| 安装方式 | Mounting position | mounting orientation |
Load is applied at 1/2 of the output shaft length when output speed reaches 100 RPM.
(The allowable axial force and allowable radial force refer to purely axial or radial loads applied independently to the output shaft.)
The actual radial force and axial force borne by the gear reducer vary depending on the load application point.
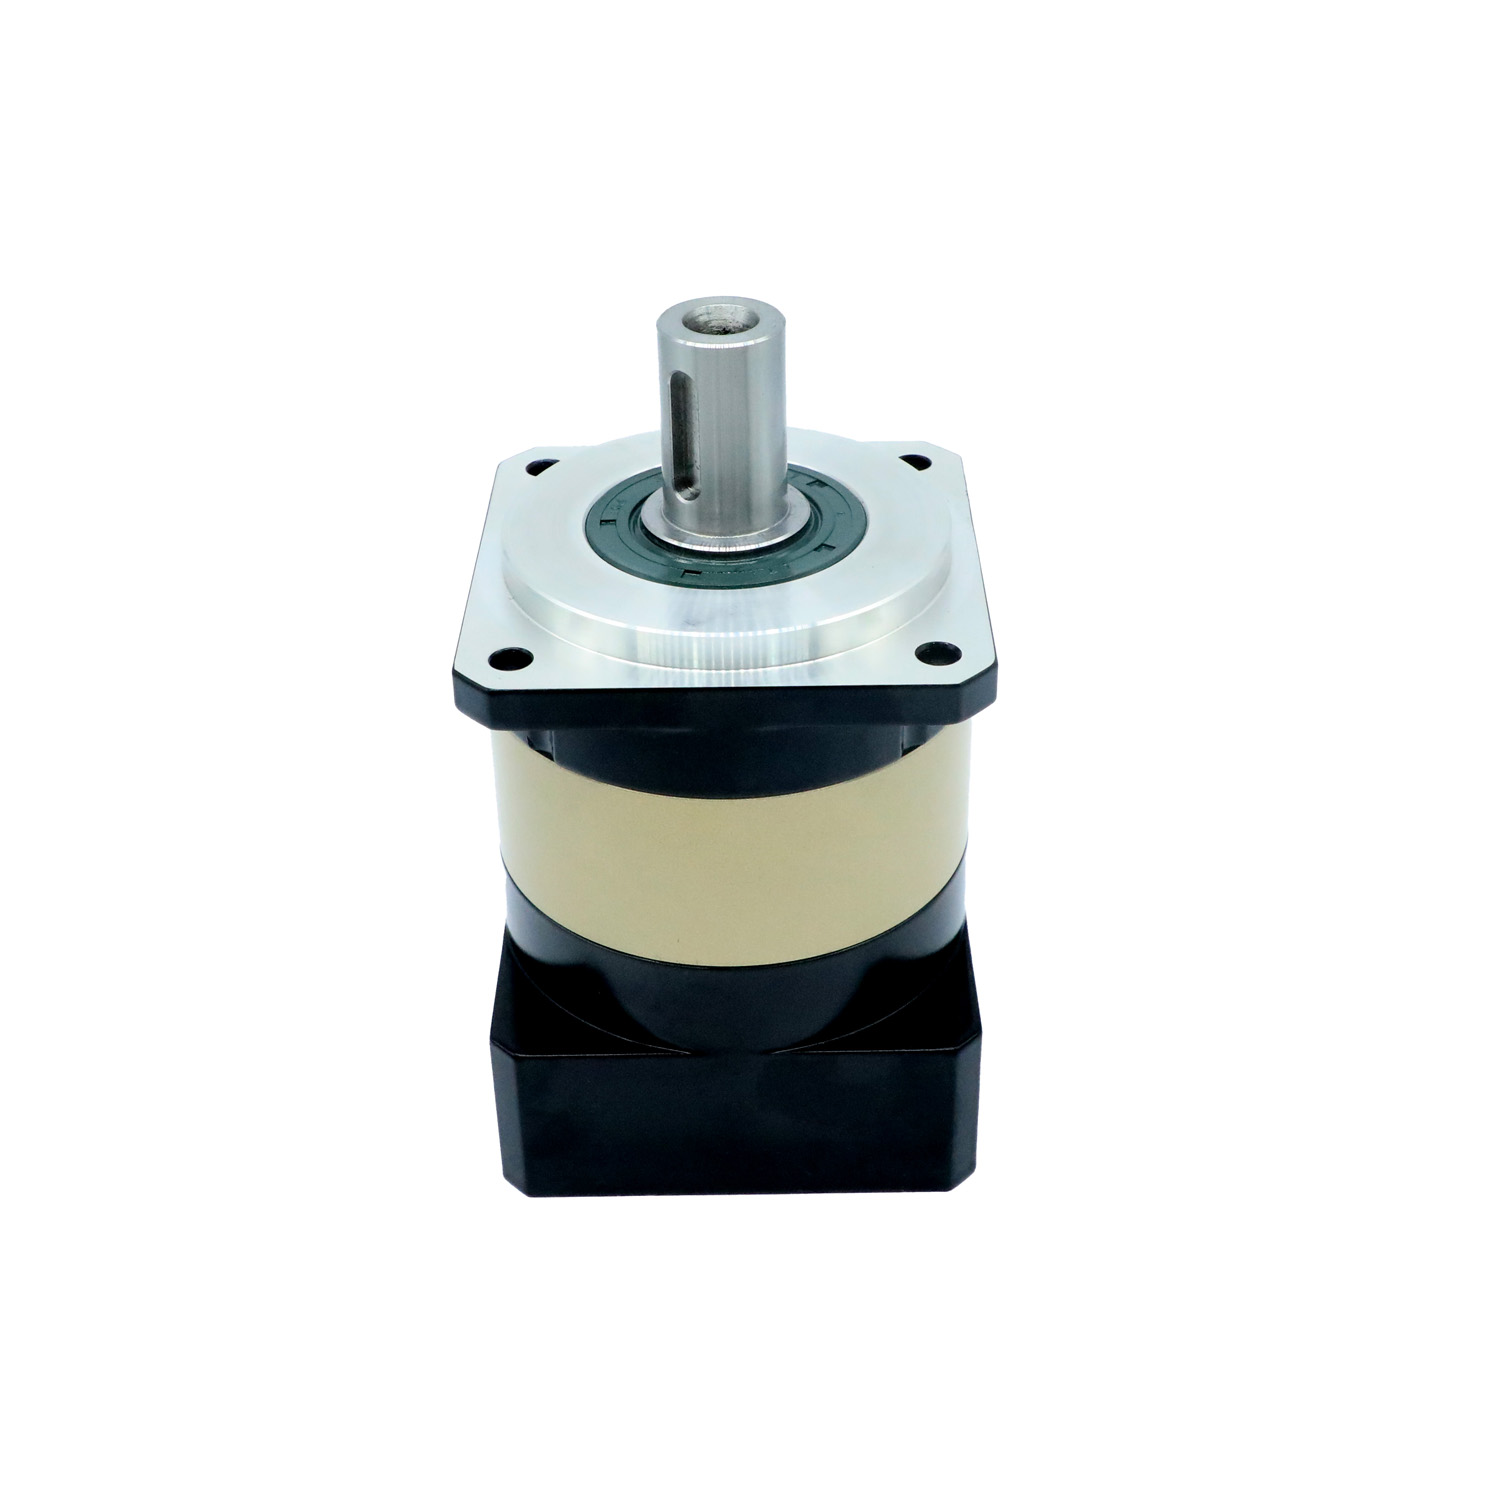
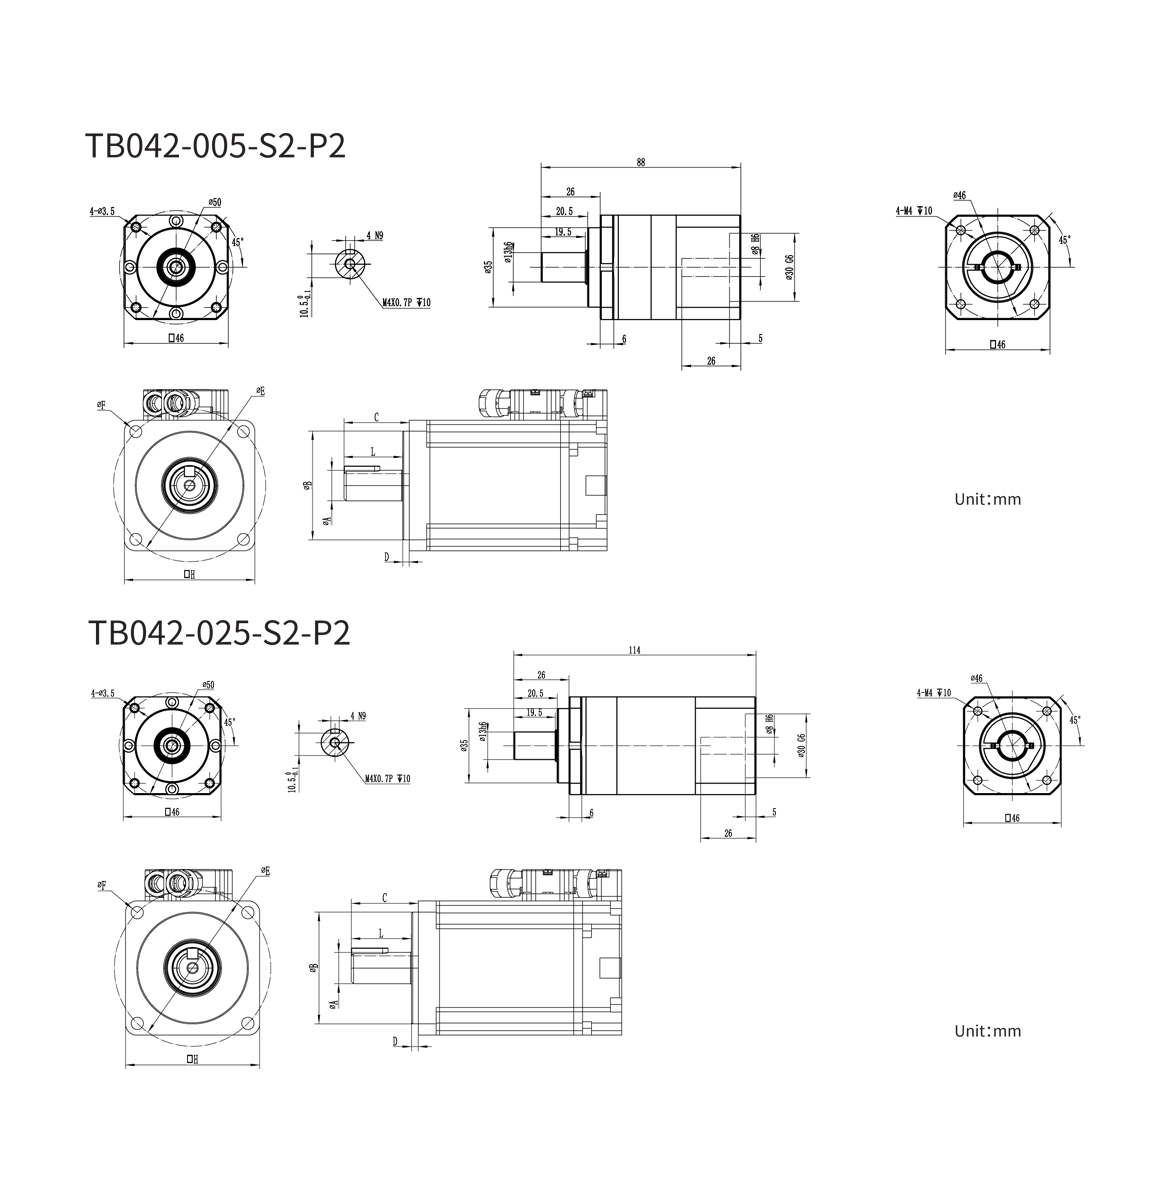
| Dimennsion | TB042 | |||
| 1-stage | 2-stage | |||
| Diameter | D1 | 50 | ||
| D2 | 3.4 | |||
| D3 | 56 | |||
| D4 | 35 | |||
| D6 | 13 | |||
| D7 | M4X0.7P | |||
| Length | L1 | 42 | ||
| L2 | 88 | 114 | ||
| L3 | 26 | |||
| L4 | 5.5 | |||
| L5 | 1 | |||
| L6 | 10 | |||
| L7 | 5.5 | |||
| L8 | 16 | |||
| Width | W1 | H9 | 5 | |
| Height | H1 | 15 | ||
| Interface size | C1 | 42 | ||
| C2 | 46 | |||
| C3 | 30 | |||
| C4 | M4X0.7P | |||
| C5 | <12 | |||
| C6 | 26 | |||
| C7 | 8.75 | |||
| C8 | 3.5 | |||
| C9 | 26 | |||
1.Maximum acceleration torque (T2B) = 0.6 × emergency stop torque (T2not)
2.Noise level varies with gear ratio. The specified value is based on a gear ratio of 10, measured at a distance of 1 meter from the reducer.
Model TB042 adopts gear ratio 8.
3.Service life is defined under operating conditions below the rated input speed and rated output speed.
*The company reserves the right to modify product dimensions. All reducer dimensions shall be subject to confirmation on official drawings.
| SPECIFICATION | ||||
| SPEC | Stage | Ratio | TB042 | |
| Rate output torque T2n(N-M) | 1 | 3 | 18 | |
| 4 | 16 | |||
| 5 | 16 | |||
| 7(8)* | 15 | |||
| 10 | 12 | |||
| 2 | 15 | 18 | ||
| 20 | 16 | |||
| 25 | 16 | |||
| 30 | 18 | |||
| 35 | 16 | |||
| 40 | 16 | |||
| 50 | 16 | |||
| 70 | 15 | |||
| 100 | 12 | |||
| Emergrncy Stop Torque T2not (N-M)(1) | 1,2 | 3~100 | 3 times the rated output torque | |
| Rate Input Speed n | rpm | 1,2 | 3~100 | 3000 |
| Max.Inptut Speed n | rpm | 1,2 | 3~100 | 5000 |
| Effciency | % | 1 | 3~100 | ≧97% |
| 2 | 15~100 | ≧95% | ||
| Standard | Stage | Ratio | TB042 |
|---|---|---|---|
| Mass Mom. of inertia.J(KG-CM^2) | 1 | 3 | 0.02 |
| 4 | 0.02 | ||
| 5 | 0.01 | ||
| 7(8)* | 0.01 | ||
| 10 | 0.01 | ||
| 2 | 15 | 0.01 | |
| 20 | 0.01 | ||
| 25 | 0.01 | ||
| 30 | 0.01 | ||
| 35 | 0.01 | ||
| 40 | 0.01 | ||
| 50 | 0.01 | ||
| 70 | 0.01 | ||
| 100 | 0.01 |
0519-88385510 / 0519-88369923
Mobile+86-15106112177 (Mr. Zhao)
Fax0519-88770911
Emailinfo@ht-motor.com
AddressIndustrial Concentration Zone, Qinxin Village, Yaoguan Town, Wujin District, Changzhou City, Jiangsu Province
0755-23310859
Mobile15986759015
AddressRoom 1601, Building 2, Science and Technology Innovation Workshop, No. 6 Songjiang Road, Shapu Community, Songgang Street, Bao